 1 / 3
Sold out · Ask us about restocking
Not available to order right now.
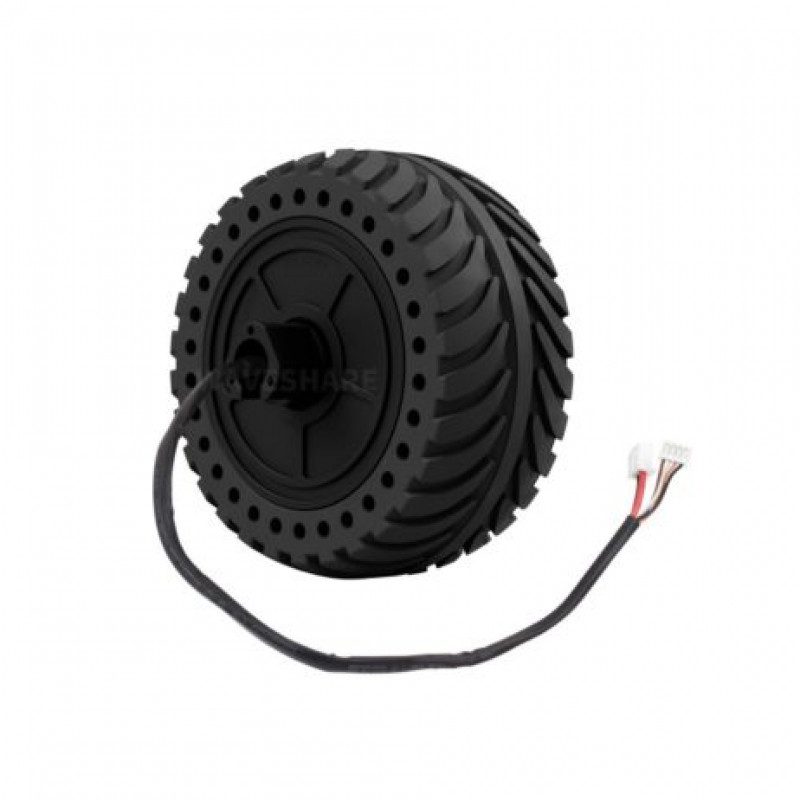
Most small robot drive wheels use a geared DC motor, which introduces backlash and gear noise that limits positioning precision - the DDSM115 sidesteps that entirely with a direct-drive design, coupling an outer-rotor permanent magnet synchronous motor (PMSM) straight to the output with no gear reduction stage at all. The result is genuinely zero-backlash motion and markedly quieter operation than a geared equivalent, since there's no gear mesh generating noise or wear.
The motor, driver, and encoder are all integrated into one compact unit, meaning a builder doesn't need to separately source and wire a motor driver board - the DDSM115 handles its own commutation and control internally, communicating with a host controller over RS485. That communication link reports back position, speed, current draw, and error codes, giving a connected controller genuine closed-loop feedback rather than operating the motor blind.
Hall-effect position sensing underlies the feedback system, and built-in over-current protection guards against stall or overload conditions damaging the motor or driver electronics. An electric braking function is also supported, letting the motor actively resist motion rather than simply coasting to a stop when commanded to halt - useful for robots needing precise, repeatable stopping behavior rather than drifting an unpredictable extra distance after a stop command.
Builders working on a precision mobile robot base, a direct-drive wheel platform, or any robotics project where gear backlash and noise would compromise positioning accuracy or quiet operation will find the DDSM115 a genuinely different approach from the geared-motor norm, trading some raw torque-multiplication for considerably cleaner, quieter, more precise motion control.
| Brand | Waveshare |
|---|---|
| Interface Type | RS485 |
| Selling unit | PCS |