 1 / 2
Sold out · Ask us about restocking
Not available to order right now.
The Pixhawk 2.4.8 full combo set brings advanced functionality and better control to aerial projects. The listing describes a versatile flight controller for fixed-wing, rotary-wing or multirotor vehicles that supports autonomous GPS missions and precise waypoint navigation.
It runs the open-source ArduPilot (APM) and PX4 systems and offers multithreading, complex mission handling and reliable performance for beginners and experts. The NEO-M8N GPS module with a 72-channel u-blox engine gives high accuracy and sensitivity.
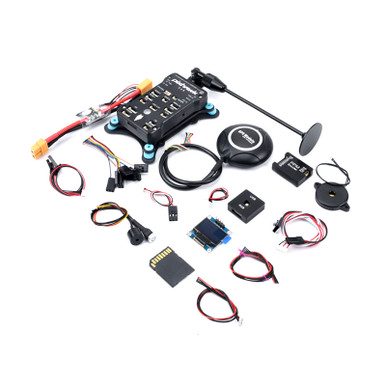
The set includes the accessories needed for a complete installation: buzzer, safety switch, power module, PPM and I2C modules, a shock absorber board, an SD card, the GPS with a holder, an OSD OLED display, DF13 cables and an RGB module.
Autonomous flight: supports fully autonomous stabilisation and waypoint navigation.
High-performance processor: 32-bit ARM Cortex M4 running NuttX RTOS.
NEO-M8N GPS: 72-channel u-blox engine for precise tracking.
Multithreading: a Unix/Linux-like environment for complex flight commands.
Telemetry support: two-way communication for real-time monitoring.
Complete accessory set: everything to wire up an aircraft.
A Pixhawk autopilot combines a fast processor with gyros, accelerometers, a barometer and a compass, and it runs autopilot software that keeps the aircraft stable and flies it along a planned route. With a GPS attached, it can hold position, return home and fly waypoint missions.
You set it up with ground-station software: install the firmware for your vehicle type, calibrate the accelerometer and compass, set up the radio and ESCs, configure the failsafes and test the motor order with the propellers removed. A safety switch prevents accidental arming, and a buzzer gives audible feedback on the state of the system.
Mount the flight controller on the shock absorber board, well away from vibration, and keep the GPS on a mast away from interference. Test every flight mode carefully and read the documentation for your vehicle type.
Multirotor, fixed-wing and rover autopilots
Autonomous GPS missions and waypoints
ArduPilot and PX4 projects
Research and education platforms
Long-range and mapping aircraft
The packing list gives the Pixhawk 2.4.8 FC, buzzer, safety switch, power module, PPM, I2C, shock absorber board, SD card, NEO-M8N GPS, GPS holder, OSD OLED display, DF13 4/5/6 pin cables and an RGB module. The description states compatibility with ArduPilot (APM) and PX4.
The page showed 12 in stock. Note that a frame, motors, ESCs, radio and battery are not part of this set.
Controller: Pixhawk 2.4.8
Processor: 32-bit ARM Cortex M4 running NuttX RTOS
GPS: NEO-M8N with 72-channel u-blox engine
Firmware: ArduPilot (APM) and PX4
Included: buzzer, safety switch, power module, PPM, I2C, shock absorber board, SD card, GPS holder, OSD OLED display, DF13 cables, RGB module
1 x Pixhawk 2.4.8 flight controller
1 x buzzer
1 x safety switch
1 x power module
1 x PPM module
1 x I2C module
1 x shock absorber board
1 x SD card
1 x NEO-M8N GPS
1 x GPS holder
1 x OSD OLED display
DF13 4/5/6-pin cables
1 x RGB module
Builders who want a complete Pixhawk 2.4.8 autopilot set with GPS and accessories.
ArduPilot (APM) and PX4.
A NEO-M8N with a 72-channel u-blox engine.
A 32-bit ARM Cortex M4 running NuttX RTOS.
Yes, along with a buzzer and a safety switch.
An OSD OLED display is listed in the packing list.
Fixed-wing, rotary-wing and multirotor autonomous vehicles.
| Brand | Readytosky |
|---|---|
| Firmware | PX4 / ArduPilot (APM) |
| Flight Controller (bundled) | Pixhawk 2.4.8 |
| Kit Includes | GPS Module |
| Processor | 32-bit ARM Cortex M4 |
| Selling unit | PCS |