Standard checkout available. Verified maker dispatch.
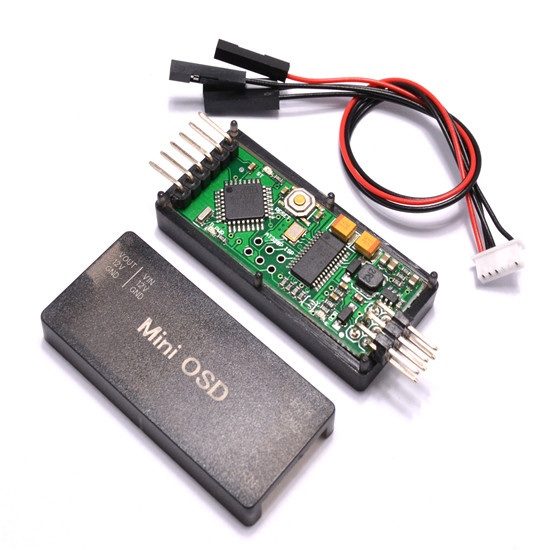
FPV flying works best when critical flight data - battery voltage, altitude, GPS status, flight mode - appears directly in the video feed itself rather than on a separate telemetry screen the pilot has to look away from the goggles to check. This module does exactly that, reading the MAVLink data stream an APM-based flight controller already produces and overlaying it onto the video signal before it reaches the video transmitter, so the information shows up right in the FPV goggles or monitor.
Built around an ATmega328P with the standard Arduino bootloader driving a MAX7456 monochrome on-screen display chip, it's firmware-flashable and configurable the same way the broader Arduino ecosystem's tools work, rather than being a sealed black box. A built-in +5V 500mA regulator accepts up to +12V supply input directly, and the standard 6-pin ISP header plus FTDI-compatible pinout keep both initial setup and any later firmware updates straightforward.
Common uses are APM and Pixhawk-based FPV builds wanting in-video telemetry display, long-range and autonomous flight projects where glancing away from goggles to check a separate screen isn't practical, and general FPV setups wanting flight-critical data overlaid directly on the video feed rather than tracked separately.
| Brand | Generic |
|---|---|
| OSD Chip | MAX7456 |
| Protocol | MAVLink |
| Weight | 12.000000 g |
| Selling unit | PCS |