 1 / 5
Sold out · Ask us about restocking
Not available to order right now.
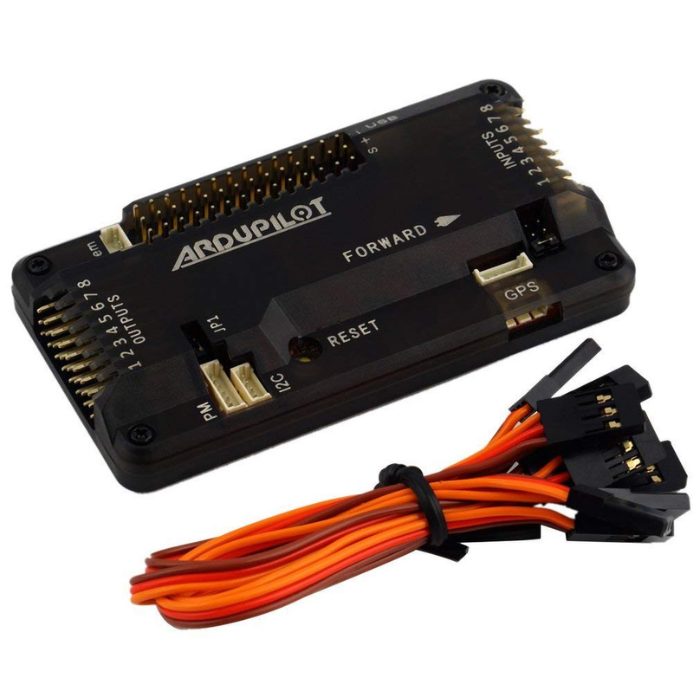
The APM 2.8 is described as an Arduino-compatible, open-source autopilot system for drones, multi-copters and rovers. This listing is the variant without a compass.
The page lists an onboard 4 MB dataflash chip for automatic data logging, optional off-board GPS capability and configuration with the downloadable Mission Planner software. It gives no processor, sensor or dimension data. The page showed 31 in stock at Rs 4,949 (SKU TIFQC0023).
Arduino compatible: an open-source autopilot system.
4 MB onboard dataflash: for automatic data logging.
Mission Planner software: for configuration.
Optional off-board GPS: as listed.
For drones, multi-copters and rovers: as described.
Without compass variant: as listed.
A flight controller is the brain of a multirotor or fixed-wing aircraft. It reads the gyroscope, and where fitted the accelerometer, barometer and compass, and runs a control loop that compares what the aircraft is doing with what the pilot asks for. It then sends new speed commands to the motors through the ESCs or servos many times each second. A faster processor and a better gyro allow a higher loop rate and a more locked-in feel.
Wiring and firmware decide what the board can do. The number of UARTs limits how many receivers, GPS units, telemetry radios and video systems you can connect, the PWM or motor outputs limit how many motors and servos it can drive, and the input voltage range must suit your battery and power module. Before you buy, check that the firmware you want to run supports the board and that its mounting pattern fits your frame.
Set up carefully. Flash a firmware that is listed as supported, configure the receiver protocol, set the motor order and direction, calibrate the accelerometer and, for larger aircraft, the compass, and always test with the propellers removed first. Keep the board isolated from vibration with soft mounts where the design calls for them, and never power it with a supply that is outside the rated input voltage.
Keep the aircraft safe. Confirm your failsafe settings and arming switch before the first flight, keep a backup of your configuration, and update firmware only when you have a reason to. A flight controller is a safety-critical part, so use the wiring diagram from the maker and avoid guesswork with power connections.
Multi-copters
Drones
Rovers
Mission Planner projects
Learning autopilot setup
The page lists no compass in this variant, so plan an external compass if you need one. GPS is optional and off-board.
The page does not give input voltage, sensor or size figures, so check the wiring and mounting before you buy.
Type: Arduino-compatible open-source autopilot
Dataflash: 4 MB onboard
GPS: optional off-board
Software: Mission Planner
Variant: without compass
1 x APM 2.8 flight controller (without compass)
Hobbyists and learners who want an open-source autopilot with Mission Planner.
No, this is the variant without compass.
4 MB onboard.
Mission Planner.
Yes, optional off-board GPS.
| Brand | Generic |
|---|---|
| Dataflash | 4MB onboard |
| Software Compatibility | Mission Planner |
| Selling unit | PCS |