 1 / 2
Standard checkout available. Verified maker dispatch.
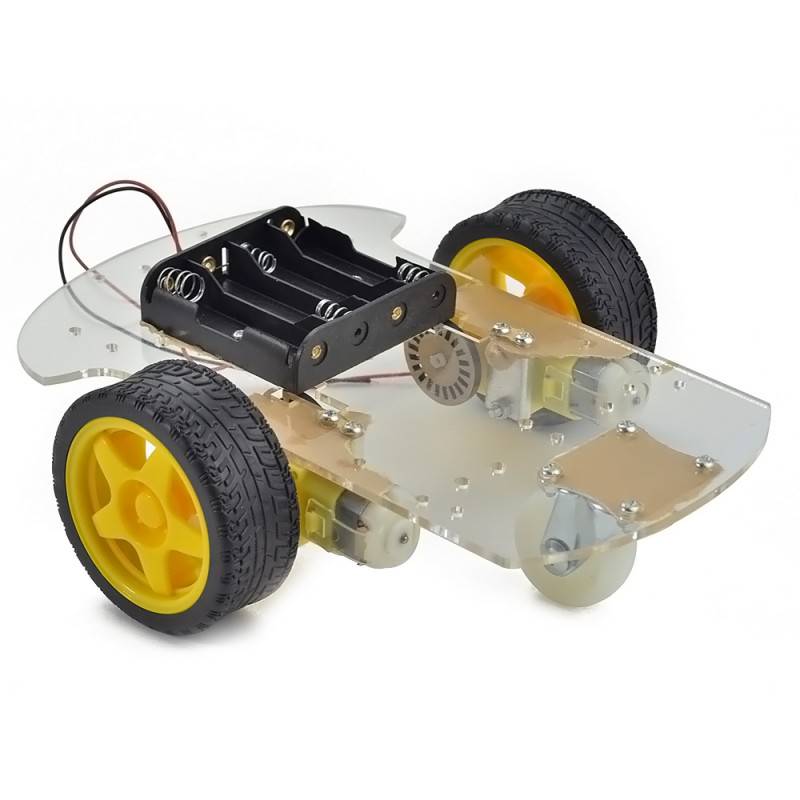
This 2-wheel smart car chassis kit gives builders a complete, ready-to-assemble base for a differential-drive robot, the simplest and most common layout for line-following, obstacle-avoidance and basic autonomous robot projects. The chassis itself is transparent, a deliberate design choice that keeps every mounted component, from the motors to any add-on sensor boards, visible rather than hidden inside an opaque shell, which is genuinely useful for a classroom setting where seeing how a robot is built matters as much as how it behaves.
Two BO gear motors drive the two main wheels, each paired with a speed encoder (a coded disk read by a sensor) that lets the robot's controller measure wheel rotation speed, effectively turning the chassis into a tachometer-equipped platform suited to distance and velocity measurement projects, not just simple forward/backward driving. A universal caster wheel at the front or rear provides a stable third point of contact without adding steering resistance, letting the two driven wheels handle both propulsion and turning.
The kit runs on a 4xAA battery box, with batteries not included, giving builders the flexibility to use whatever battery type is already on hand or easiest to source locally. Overall chassis dimensions are 21 x 15cm, and the wheels measure 6.5cm in diameter by 2.7cm in height, a standard size that matches widely available BO-motor wheel replacements if one is ever damaged.
The package includes the chassis, two BO gear motors, two tires, one universal wheel, two speed encoders, two fasteners, a battery box, and all necessary screws and nuts, meaning nothing extra needs sourcing to get a basic rolling robot assembled. Students, educators and hobbyists building a first line-following or obstacle-avoidance robot, especially one that benefits from speed-encoder feedback for more sophisticated motor control, will find this kit a complete, well-equipped starting point.
| Brand | Generic |
|---|---|
| Selling unit | PCS |